modelReadiness 76 out of 100, based on catalog evidence rather than task performanceGR00T N1
NVIDIA
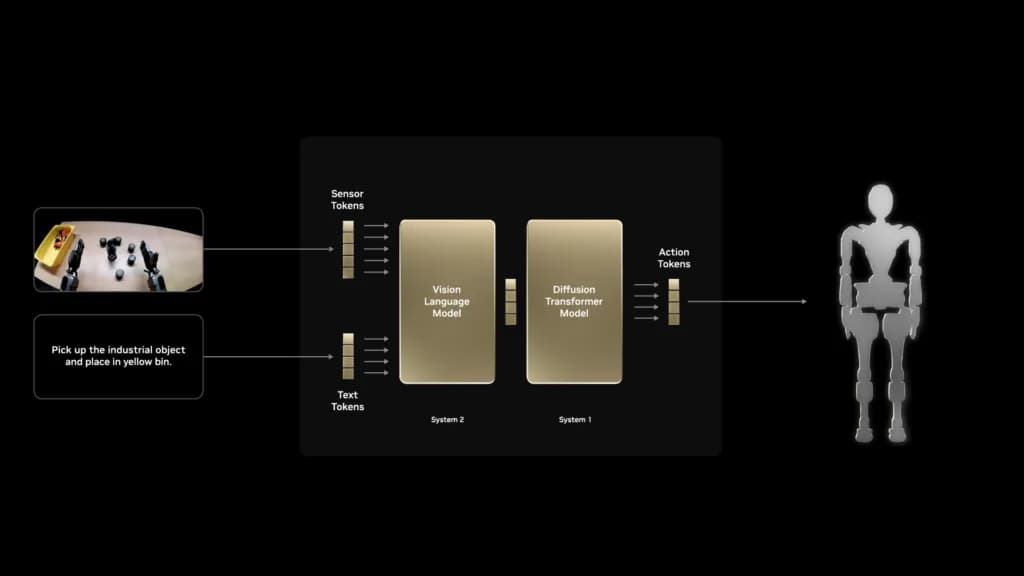
Open foundation model for generalist humanoid robots, focused on whole-body and manipulation behavior from multimodal robot data.
Find the right datasets and models, validate robot data before it reaches training, and compile it for the next run.
Selected for source evidence, usability, adoption, freshness, and distinct value. Cards show Selection readiness.
3 selected from 364
Datasets + models
modelReadiness 76 out of 100, based on catalog evidence rather than task performanceNVIDIA
Open foundation model for generalist humanoid robots, focused on whole-body and manipulation behavior from multimodal robot data.
modelReadiness 76 out of 100, based on catalog evidence rather than task performanceHugging Face LeRobot
Compact open vision-language-action policy designed for practical robot fine-tuning and deployment through the LeRobot ecosystem.
datasetReadiness 77 out of 100, based on catalog evidence rather than task performanceHugging Face · ropedia-ai/xperience-10m
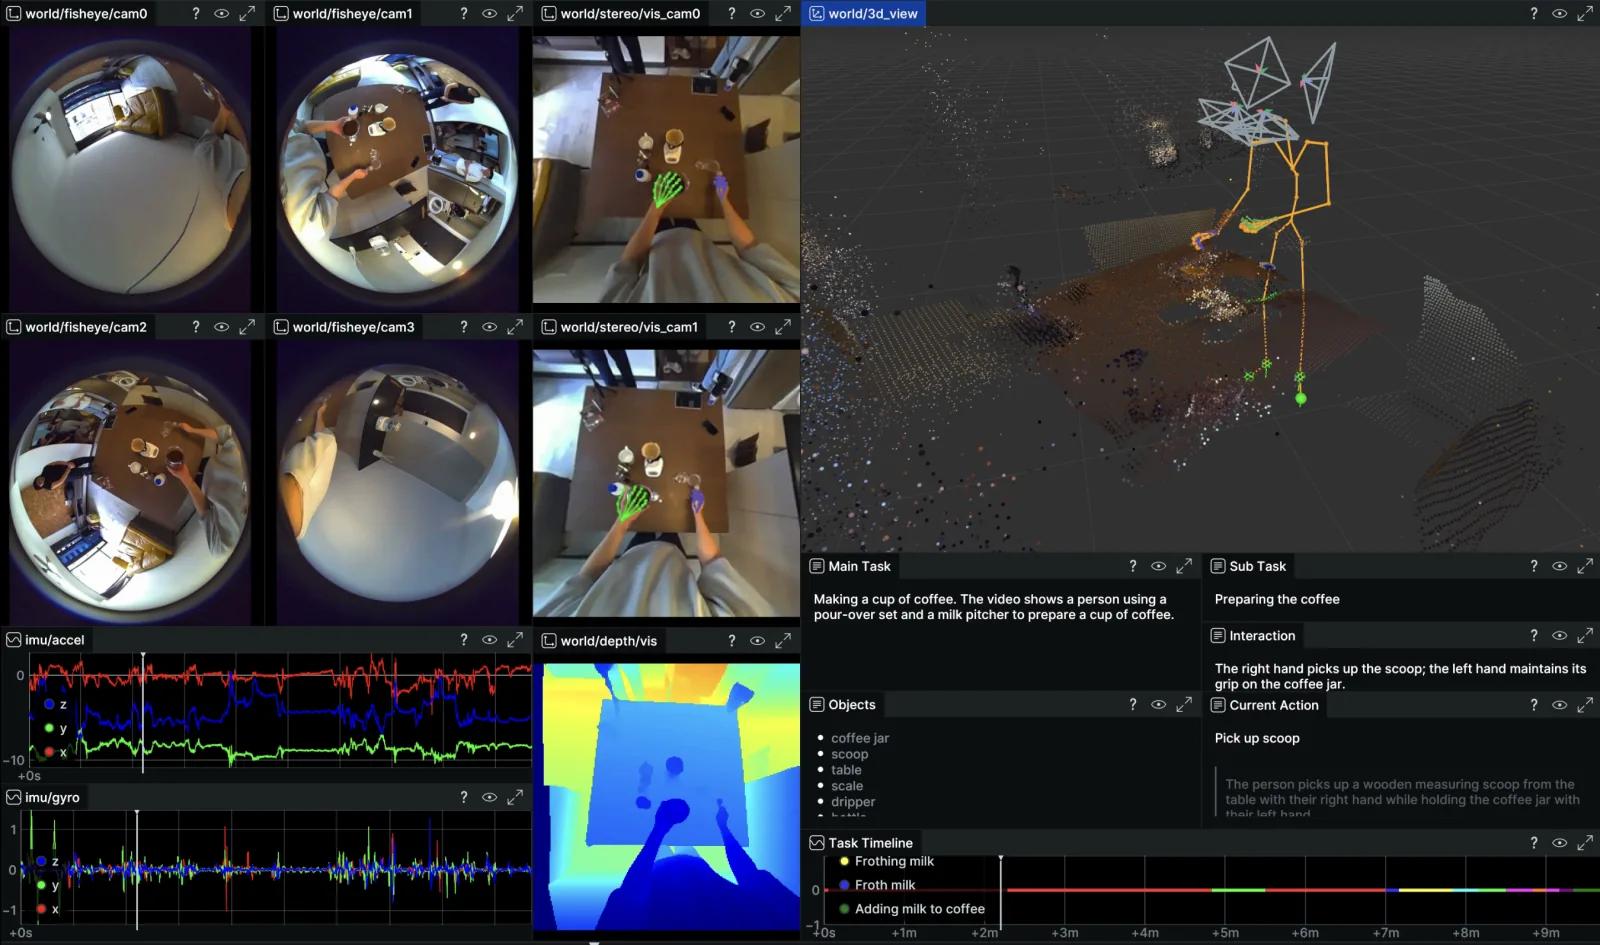
A large egocentric multimodal dataset with synchronized video streams, audio, depth, poses, mocap, IMU, and hierarchical language annotations.
Each step narrows uncertainty and leaves a result the team can review.
Open the official repository, paper, or project page.
Compare access, license, modalities, artifacts, and adoption.
Audit the exact dataset revision with openbot-data.
Use, defer, repair, or reject—with the reason preserved.
openbot-data
Inspect a robot-video or LeRobot dataset locally. Nothing is uploaded, and every result stays reviewable before the next run.
Install openbot-datapip install openbot-data
openbot-data audit ./lerobot_dataset \
--format lerobot \
--integrity full \
--out ./audit.json \
--fail-on error
openbot-data readiness ./lerobot_dataset \
--profile lerobot-act \
--integrity full \
--out ./readiness.json