OpenBot
Back to datasets

297 dated dataset releases

Dataset releases.

Browse published dataset records with source-backed, day-level release dates. Results stay pinned to one Catalog generation as you move between pages.

297 records

Source-backed datasets.

FineART official Hugging Face repository card.
Dataset Release
Unknown

FineART

lerobot · 2026-10-12

FineART: Fine-Grained Annotated Robotic Trajectory Dataset FineART is co-released by Scale AI and Hugging Face LeRobot. The data was collected and annotated by the Physical AI unit at Scale AI. FineART is a bimanual manipulation dataset where every episode comes with dense, human-written subtask annotations. It has 40,543 teleoperated episodes (1,718…

ManipulationLicense · cc-by-4.0ActionsVideo / RGB
77
Readiness

25.1K downloads

28% confidence · verified 2026-10-22

View record
unitree-g1-hardware-modifications official Hugging Face repository card.
Dataset Release
Unknown

unitree-g1-hardware-modifications

lerobot · 2026-08-28

Unitree G1 Hardware Modifications Custom 3D-printable parts and reference photos for modifying the Unitree G1: OpenArm grippers on the wrists, an extra head camera, and a backpack enclosure for the CAN-FD interface and cabling. Everything here is printable geometry plus photos of the assembled result — there is no firmware or control code in this repo.…

ManipulationLicense · apache-2.0Video / RGB
—
Readiness

979 downloads

Not scored · verified 2026-10-22

View record
EgoSuite-Open100K project overview
Dataset Series
Open

EgoSuite-Open100K

Lightwheel · 2026-08-07

EgoSuite-Open100K is a large egocentric corpus of people performing everyday work tasks, captured on a head rig with stereo cameras and — on the EgoPro line — a camera on each wrist. Recordings carry 3D hand pose, full-body pose on the body subsets, and subtask-level semantic segments, and ship in LeRobot v3 and MCAP. Read the hours claim carefully. The…

EgocentricLicense · customVideo / RGBLanguage / text
73
Readiness

362K episodes

48% confidence · verified 2026-10-21

View record
ArmnetBench v0.1 Dataset Front camera.
Dataset Series
Open

ArmnetBench v0.1 Dataset

Armnet · 2026-07-27

ArmnetBench v0.1 is a real-world manipulation benchmark: 7 policies run on a fleet of low-cost SO-101 cells, with every episode human-scored. It is released as evaluation data rather than a training corpus, which makes it unusual here — most of the catalog is demonstrations, and this is what happens when policies actually try. What is in it. 3,718 episodes…

ManipulationLicense · Apache-2.0Video / RGB
70
Readiness

3,718 episodes

35% confidence · verified 2026-10-08

View record
community_dataset_v3 official Hugging Face repository card.
Dataset Release
Unknown

community_dataset_v3

lerobot · 2026-07-16

Lerobot Community Datasets v3 - A Cross-Embodiment Pretraining Dataset for Vision Language Action Models A large-scale robotics dataset for vision-language-action learning, featuring 791 datasets across 46 robot types, enabling cross-embodiment pretraining for generalist robot policies. Overview This is a crowdsourced, open-source dataset compiled from 235…

ManipulationLicense · apache-2.0ActionsLanguage / text
—
Readiness

32.1K downloads

Not scored · verified 2026-10-22

View record
RoboDojo Real-world tasks.
Dataset Series
Open

RoboDojo

MMLab@HKU and collaborators · 2026-07-05

RoboDojo is a sim-and-real evaluation benchmark built to answer a blunt question: how good are generalist manipulation policies really? The answer it reports is sobering — the best of 30 policies evaluated in simulation reached only 8.80% success against 76.03% for human teleoperation. 60 tasks total: 42 simulation tasks (NVIDIA Isaac Sim 5.1 / Isaac Lab…

ManipulationLicense · Apache-2.0Video / RGBDepth / 3D
77
Readiness

5,300 episodes

48% confidence · verified 2026-10-08

View record
HABIT (Human Aware Behavior and Interaction Training dataset) dataset sample.
Dataset Series
Open

HABIT (Human Aware Behavior and Interaction Training dataset)

Config · 2026-06-30

HABIT (Human-Aware Behavior and Interaction Training dataset) is a large-scale robot manipulation dataset collected in human-present environments, where a co-present human shares the workspace and interacts with the robot in every episode. 10,563 episodes, 164 hours of bimanual manipulation across 60 tasks Organized into three human-robot interaction roles…

ManipulationLicense · CC-BY-4.0Video / RGBLanguage / text
73
Readiness

10.6K episodes

48% confidence · verified 2026-10-08

View record
abc_130k_v3_train official Hugging Face repository card.
Dataset Release
Unknown

abc_130k_v3_train

lerobot · 2026-06-29

This dataset was created using LeRobot. Dataset Structure meta/info.json: { "codebaseversion": "v3.0", "fps": 30, "features": { "observation.state": { "dtype": "float32", "shape": [ 14 ], "names": [ "leftarmjoint1", "leftarmjoint2", "leftarmjoint3", "leftarmjoint4", "leftarmjoint5"… See the full description on the dataset page:…

ManipulationLicense · apache-2.0Robot state / trajectoryVideo / RGB
73
Readiness

24.8K downloads

33% confidence · verified 2026-10-22
View record
outdoor-depth official Hugging Face repository card.
Dataset Release
Unknown

outdoor-depth

lerobot · 2026-06-25

This dataset was created using LeRobot. Dataset Structure meta/info.json: { "codebaseversion": "v3.0", "fps": 30, "features": { "observation.images.depth": { "dtype": "image", "shape": [ 720, 1280, 1 ], "names": [ "height", "width", "channels" ], "info": { "isdepth_map":… See the full description on the dataset page:…

ManipulationLicense · apache-2.0Video / RGBDepth / 3D
82
Readiness

247 downloads

21% confidence · verified 2026-10-22

View record
ABC-130k dataset sample.
Dataset Series
Open

ABC-130k

UC Berkeley / MIT / Amazon FAR / CMU / XDOF · 2026-06-25

ABC-130k is an open bimanual robot manipulation dataset released with the paper 'Scalable Behavior Cloning with Open Data, Training, and Evaluation'. It contains roughly 130,919 episodes (43,090 annotated) totaling about 3,598 hours collected on bimanual YAM stations with two 6-DoF arms and parallel-jaw grippers, spanning ~195 tasks such as pick-and-place,…

ManipulationLicense · Apache-2.0Video / RGBLanguage / text
73
Readiness

130.9K episodes

48% confidence · verified 2026-10-08

View record
HIW-500: Humanoids In-the-Wild dataset sample.
Dataset Series
Open

HIW-500: Humanoids In-the-Wild

BitRobot · 2026-06-25

HIW-500 (Humanoids In-the-Wild) is a large-scale dataset for whole-body humanoid robot learning in natural home environments, capturing human teleoperation demonstrations on the Unitree G1 across 12 real homes in Southeast Asia. It contains 500+ hours and 23K+ episodes spanning 10+ household tasks with 161 subtask labels (~10 TB). Each episode records…

ManipulationLicense · unknownVideo / RGBDepth / 3D
77
Readiness

23K episodes

48% confidence · verified 2026-10-09

View record
abc_130k_v3_val official Hugging Face repository card.
Dataset Release
Unknown

abc_130k_v3_val

lerobot · 2026-06-24

This dataset was created using LeRobot. Dataset Structure meta/info.json: { "codebaseversion": "v3.0", "fps": 30, "features": { "observation.state": { "dtype": "float32", "shape": [ 14 ], "names": [ "leftarmjoint1", "leftarmjoint2", "leftarmjoint3", "leftarmjoint4", "leftarmjoint5"… See the full description on the dataset page:…

ManipulationLicense · apache-2.0Robot state / trajectoryVideo / RGB
73
Readiness

1.5K downloads

33% confidence · verified 2026-10-22

View record
abc_130k_v3_smoke official Hugging Face repository card.
Dataset Release
Unknown

abc_130k_v3_smoke

lerobot · 2026-06-24

This dataset was created using LeRobot. Dataset Structure meta/info.json: { "codebaseversion": "v3.0", "fps": 30, "features": { "observation.state": { "dtype": "float32", "shape": [ 14 ], "names": [ "leftarmjoint1", "leftarmjoint2", "leftarmjoint3", "leftarmjoint4", "leftarmjoint5"… See the full description on the dataset page:…

ManipulationLicense · apache-2.0Robot state / trajectoryVideo / RGB
73
Readiness

9.2K downloads

33% confidence · verified 2026-10-22
View record
LeRobot Shirt-Folding Dataset dataset sample.
Dataset Series
Open

LeRobot Shirt-Folding Dataset

LeRobot (Hugging Face) · 2026-06-22

The shirt-folding dataset from LeRobot's open-source 'Unfolding Robotics: Open-Source Shirt Folding from Data to Deployment' project, which trained a bimanual robot to fold t-shirts at a 90% success rate. Collected via real-world leader-follower teleoperation across 8 bimanual setups optimizing for diversity (25+ t-shirts, 8 backgrounds, varied camera/robot…

ManipulationLicense · Apache-2.0Video / RGB
70
Readiness

5,688 episodes

42% confidence · verified 2026-10-09

View record
EgoInfinity Recovered 4D hand-object interaction.
Dataset Series
Open

EgoInfinity

Rice RobotPI Lab · 2026-06-16

EgoInfinity is not a static dataset but a modular, upgradable data engine: it takes ordinary internet video of people manipulating objects and automatically recovers metric 4D hand–object interaction, then retargets that motion into executable robot joint trajectories — no manual annotation and no depth sensors. Runs over Meta FAIR's Action100M corpus —…

EgocentricLicense · customVideo / RGBDepth / 3D
77
Readiness

1,150 episodes

48% confidence · verified 2026-10-08

View record
LESS (Local Encoder for Spatial Sensing) Data collection rig.
Dataset Series
Open

LESS (Local Encoder for Spatial Sensing)

Technion – Israel Institute of Technology · 2026-06-12

LESS ("More with LESS: Local Scene Representations for Tactile Imaging", RSS 2026) tackles artificial palpation — reconstructing what is inside a soft object purely by touching it. The motivating application is breast cancer screening, where over 40% of cases are first detected by palpation. >800 hours of robotic tactile interaction, released as ~66 GB…

ManipulationLicense · CC-BY-4.0Pose / calibrationTactile / force
70
Readiness

800 hours

35% confidence · verified 2026-10-10

View record
FTP-1 Dataset dataset sample.
Dataset Series
Open

FTP-1 Dataset

FTP-1 (Yuan et al.) · 2026-06-11

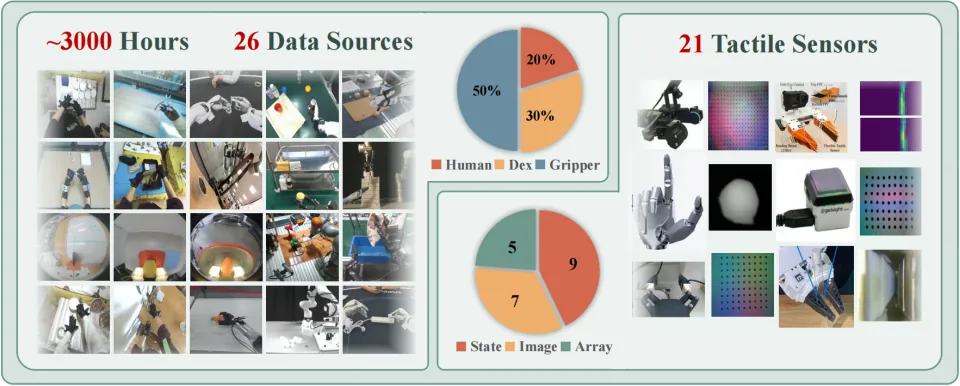
FTP-1-Dataset is the heterogeneous pretraining corpus behind FTP-1 (A Generalist Foundation Tactile Policy Across Tactile Sensors for Contact-Rich Manipulation). It aggregates roughly 3,000 hours of contact-rich manipulation data from 26 sources spanning human demonstrations, dexterous-hand, and gripper robots, recorded with 21 distinct tactile sensors…

ManipulationLicense · MITVideo / RGBLanguage / text
73
Readiness

3,000 hours

48% confidence · verified 2026-10-08

View record
MolmoAct Dataset dataset sample.
Dataset Series
Open

MolmoAct Dataset

Allen Institute for AI (Ai2) · 2026-05-04

Ai2's self-collected MolmoAct real-robot manipulation dataset, used to train MolmoAct action reasoning models, covering household and tabletop domains. The Household split has 7,529 episodes across 115 tasks with varying viewpoints; the Tabletop split adds 2,959 episodes across 19 tasks with a fixed exocentric camera (~10,488 episodes total). It uses a…

ManipulationLicense · Apache-2.0Video / RGBLanguage / text
73
Readiness

10.5K episodes

48% confidence · verified 2026-10-08

View record